
Embedded Industrial AI Assistant
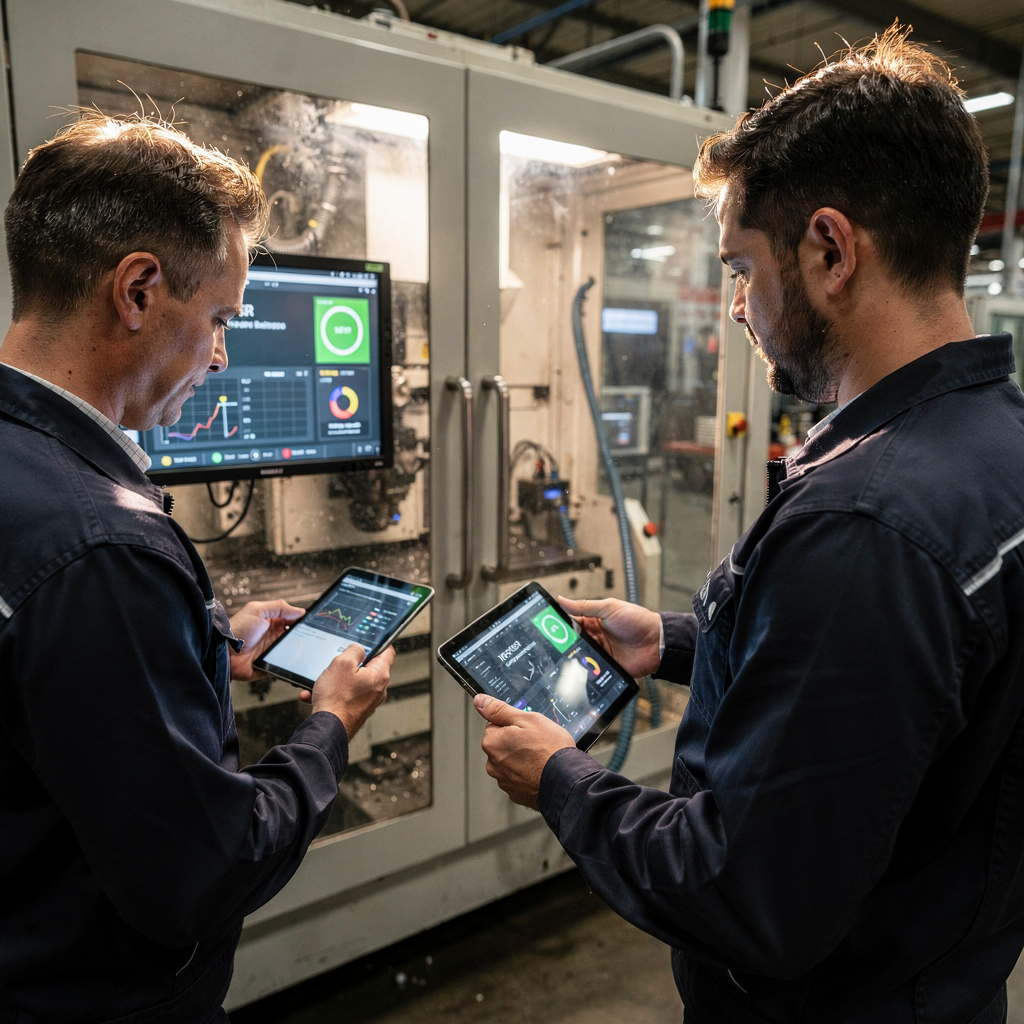
Designed an assistant for heavy equipment environments, combining speech recognition, retrieval-augmented generation, text-to-speech, and domain-specific language-model fine-tuning.
ASRRAGTTSLLM Fine-tuning
Robotics, Computer Vision & AI Engineer
Robotics · Edge AI · LLMs · Python & C++
I build robotics, computer vision and LLM-based systems, from model integration and fine-tuning to edge deployment, monitoring, and production applications.

I’m a Robotics, Computer Vision & AI Engineer who builds systems that move from prototypes into real-world environments: NVIDIA Jetson devices, industrial equipment, and robotics simulations.
I work end to end across model integration and task-specific fine-tuning, application development, deployment, and monitoring. Currently, I’m a Founding AI & Robotics Engineer at IAMAI Simulations, building simulation infrastructure to train, test, and validate drone autonomy systems.
My work includes embedded AI assistants, edge computer-vision pipelines, and simulation infrastructure for autonomous systems. I enjoy turning complex research and platform constraints into dependable engineering systems.
Based in Buenos Aires, I work in English, Spanish, and Hebrew.
 C++
 Python
 Java
 PyTorch
 OpenCV
 CUDA
 YOLO · DETR · Vision Transformers
 LLMs & Fine-tuning
 RAG
 ASR & TTS
 Unreal Engine
 ROS
 Android
 Docker
 Google Cloud
 BalenaOS
 Git
 CMake
 Bazel
NVIDIA Jetson
 Grafana
 Prometheus
 Spanish
 English
 Hebrew

As a founding engineer of a very small company, I work wherever it's needed most, from implementing core features and improving developer workflows to supporting our open-source community and helping shape technical direction.
Responsibilities:
Designed and implemented an embedded virtual assistant for industrial heavy machinery, including loaders, excavators, and aerial lifts.

Developed simulation tools to generate artificial datasets for training
AI-based aircraft navigation algorithms, ensuring compliance with specific requirements.
Used C++ for core development and Unreal Engine for high-fidelity
visual rendering, enhancing the realism of simulations.
Also I employed Python for implementing ROS nodes and handling API
client calls, effectively integrating various technologies to produce
robust and accurate training environments.

Simulation, integration, and validation workflows for autonomous systems built on the open-source Project AirSim platform.
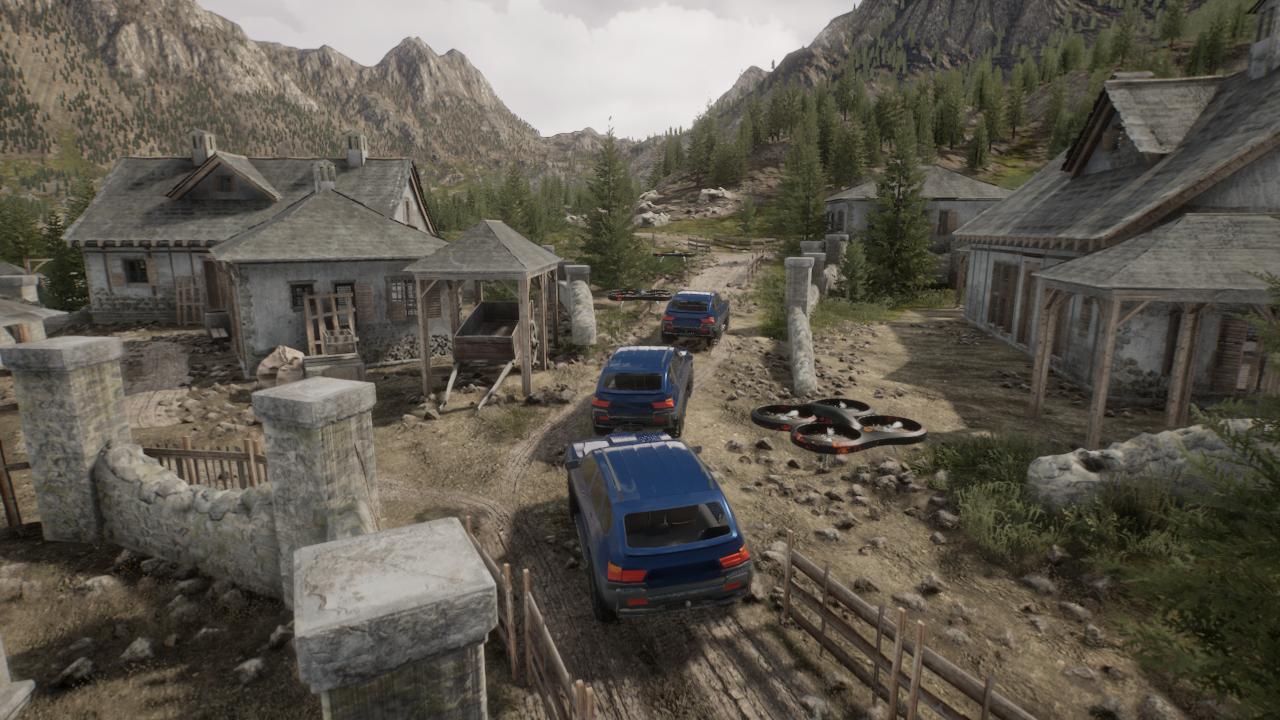
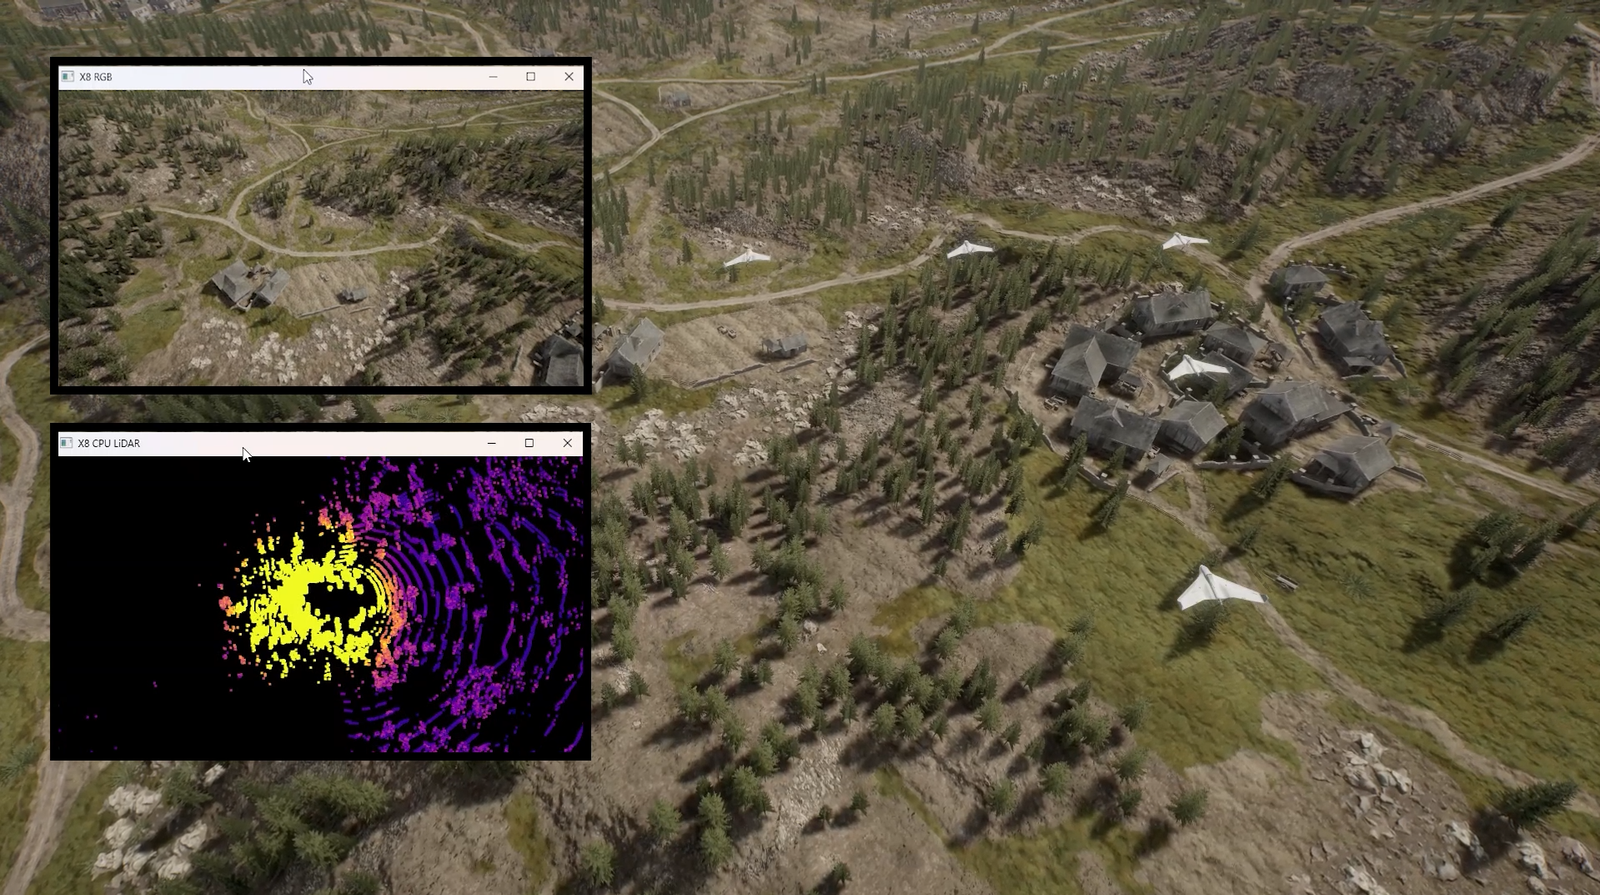
I work on simulation infrastructure for drone autonomy systems, helping teams configure environments, vehicles, sensors, controllers, and client integrations for development and validation.
Selected technical work across industrial AI, edge computer vision, and applied model fine-tuning.
Designed an assistant for heavy equipment environments, combining speech recognition, retrieval-augmented generation, text-to-speech, and domain-specific language-model fine-tuning.
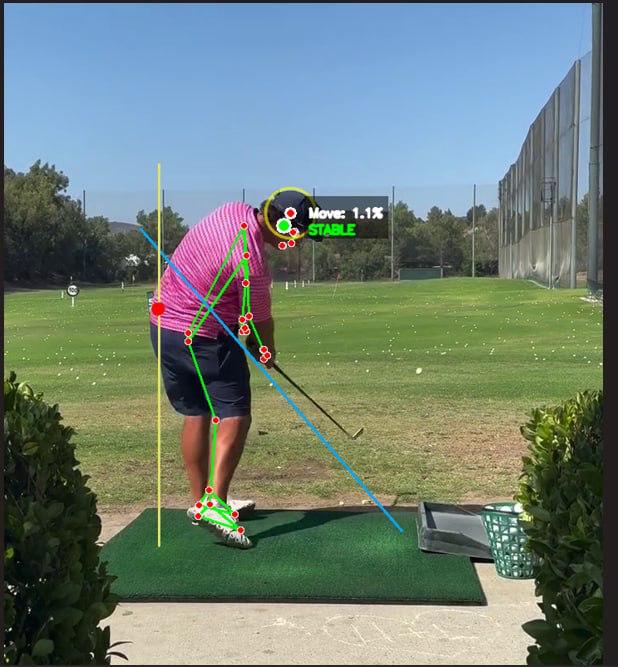
An advanced golf swing analysis system using MediaPipe pose detection, OpenCV, and NumPy. It identifies swing phases with a custom-trained vision-transformer classifier and provides annotated visualizations.
Built with an extensible architecture, REST-ready FastAPI interface, CLI, structured logging, and pytest coverage. The deployment uses AWS Lambda with RunPod GPU, and an LLM chat layer provides AI-powered swing feedback through OpenAI, Gemini, and Grok.
Built and deployed a Python analytics pipeline on NVIDIA Jetson that turns fixed-camera match footage into annotated video, player tracking data, and court heatmaps.
Integrated court calibration, 2D ball tracking, pose overlays, and player identity linking. Generated time-weighted heatmaps for all four players, including observation coverage and explicit handling of missing data.
An end-to-end computer-vision pipeline for indoor logistics and retail-style scenes, using fabric rolls as the primary inventory object and people as co-occurring actors.
Transforms ordered frame streams from disk, extracted video, or upstream capture into versioned, machine-consumable annotations and optional visual deliverables.